Skip to content

"We're here to put a dent in the universe."

Steve Jobs

Research engineer · product builder

I build AI systems that still work on the second Tuesday of the month.

Who do you think you’re looking at? When the model breaks, I don’t call someone else, Skyler. I’m the one they call. Agentic systems, LLM post-training, 2D and 3D perception. You see a demo run once on clean data and think that’s the job? No. I’m not the one watching the demo. I’m the one who ships.

I've always looked at the stars and wondered about our place in the universe. From both physical and spiritual perspectives, I keep returning to two questions: Who am I, and where do we go next as a civilization? I also love history, financial markets, geopolitics, and theology. I reset by running, hiking, or lifting; play football, cricket, and tennis; and unwind with sitcoms.

I'm also a firm believer in e/acc and in our ability to solve difficult problems when we set aside our differences and work toward becoming a Type I civilization on the Kardashev scale. AI and robotics will play a major role in that journey.
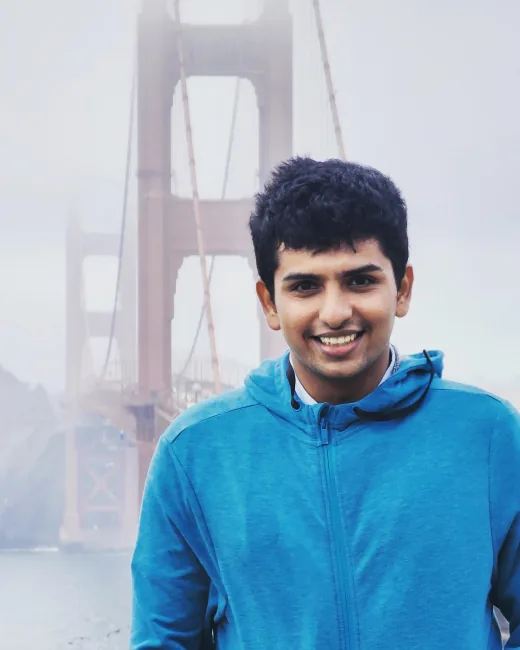
Param Dave standing in front of a fog-covered Golden Gate Bridge.
Golden Gate Bridge. Man, was it windy. Photo: successful. Health: less so.

How I work

Start with the outcome, then reason from first principles.

I move from an outcome to the uncertainty blocking it, test what matters, and use production evidence to decide what the next iteration should be.

01 / Guiding question

What should become measurably better for the user or the business?

In practice

For document intelligence, better OCR was not enough. The target was 100% decision accuracy: when the system compared outputs, it had to identify the correct one and reject the incorrect one, with no ambiguous result.

Output
Success criteria and constraints
Decision rule
Optimize for the outcome, not the most interesting technique.

Production evidence loops back into the next outcome. This is a cycle, not a handoff.

Now

Aug 2026

Shipping

Agent eval harness design across multiple projects and 3D reasoning on outdoor imagery.

Investigating

  • How do you ground VLM and LLM reasoning through post-training, from PPO and GRPO to perception-aware objectives like PAPO?
  • How do you make robotics policies generalize under conditions they were not trained for?
  • How do you close the gap between inference benchmarks and production behavior?

My favorite kind of problem

The ones where the paper says 94% and your data says otherwise.

I close that gap for a living — evaluation, post-training, and the model work underneath it. The application layer is downstream of getting that part right.

Start a conversation →